- Torso Adjusts 116-165 cm The working height changes with the task instead of forcing the bench or shelf to change.
- 29 Degrees of Freedom Seven per arm, two in the head, three in the waist, eight in the base and two in the folding lower limbs, excluding end effectors.
- 16 kg Dual-Arm Payload Both arms together are rated for 16 kilograms, with repeat positioning accuracy of plus or minus 0.1 millimetre.
- Four Hours on Hot-Swappable Packs Two 720 watt-hour batteries on a 48-volt platform run for four hours and can be exchanged rather than waiting out a two-hour charge.
- Dense Sensor Package One RGB structured-light depth camera, four depth cameras, eight ultrasonic radars, two LiDARs and a six-axis IMU cover close manipulation and room-scale navigation.
- Ubuntu on Ryzen, EtherCAT Joints Ubuntu 22.04 runs on an AMD Ryzen processor with Type-C, USB 3.0 and RJ45, and the joints communicate over EtherCAT.
- Optional High-Compute Module A Jetson AGX Orin or Thor module can be fitted where onboard model inference is part of the project.

Description
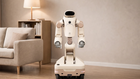
The GRW is Fourier's wheeled dual-arm platform for mobile manipulation, laboratory automation and service work. Its torso adjusts between 116 and 165 centimetres, so the same machine can work at a low bench, a standard counter and a high shelf without changing the task layout. It occupies a 72.0 by 61.8 centimetre footprint and weighs about 160 kilograms.
The articulation is where the specification is unusual for a wheeled robot: 29 degrees of freedom excluding end effectors, split as 7 per arm, 2 in the head, 3 in the waist, 8 in the base and 2 in the folding lower limbs. The dual-arm rated payload is 16 kilograms and repeat positioning accuracy is plus or minus 0.1 millimetre, which puts it in reach of laboratory tasks where a service robot usually is not considered.
Power and compute are built for long sessions. A 48-volt platform draws about 1,200 watts rated, two 720 watt-hour batteries give a four-hour runtime with roughly two hours to recharge, and the packs are hot-swappable. Onboard it runs Ubuntu 22.04 on an AMD Ryzen processor with Type-C, USB 3.0 and RJ45, and an optional Jetson AGX Orin or Thor module adds high-end inference. Joint communication is over EtherCAT.
Sensing is dense for the class: one RGB structured-light depth camera, four further depth cameras, eight ultrasonic radars, two LiDARs, a six-axis IMU and a 5-watt speaker. End effectors, software packages and integration scope are specified with the quotation. Typical buyers are research groups, laboratory automation teams and commercial operators trialling human-machine collaboration.
Key Capabilities
- Torso Adjusts 116-165 cm: The working height changes with the task instead of forcing the bench or shelf to change.
- 29 Degrees of Freedom: Seven per arm, two in the head, three in the waist, eight in the base and two in the folding lower limbs, excluding end effectors.
- 16 kg Dual-Arm Payload: Both arms together are rated for 16 kilograms, with repeat positioning accuracy of plus or minus 0.1 millimetre.
- Four Hours on Hot-Swappable Packs: Two 720 watt-hour batteries on a 48-volt platform run for four hours and can be exchanged rather than waiting out a two-hour charge.
- Dense Sensor Package: One RGB structured-light depth camera, four depth cameras, eight ultrasonic radars, two LiDARs and a six-axis IMU cover close manipulation and room-scale navigation.
- Ubuntu on Ryzen, EtherCAT Joints: Ubuntu 22.04 runs on an AMD Ryzen processor with Type-C, USB 3.0 and RJ45, and the joints communicate over EtherCAT.
- Optional High-Compute Module: A Jetson AGX Orin or Thor module can be fitted where onboard model inference is part of the project.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Fourier |
|---|---|
| Model | GRW |
| Product Type | Wheeled dual-arm robot |
| Height Range | 116-165 cm, adjustable |
| Footprint | 72.0 x 61.8 cm |
| Net Weight | Approximately 160 kg |
| Degrees of Freedom | 29 excluding end effectors: 7 per arm, 2 head, 3 waist, 8 base, 2 folding lower limb |
| Dual-Arm Rated Payload | 16 kg |
| Repeat Positioning Accuracy | +/-0.1 mm |
| Electrical Platform | 48 V, approximately 1,200 W rated power |
| Batteries | 720 Wh + 720 Wh, hot-swappable |
| Runtime | 4 hours |
| Charging Time | Approximately 2 hours |
| Operating System | Ubuntu 22.04 |
| Processor | AMD Ryzen |
| Optional Compute | Jetson AGX Orin or Thor high-compute module |
| Interfaces | Type-C, USB 3.0, RJ45 |
| Joint Communication | EtherCAT |
| Sensors | 1 RGB structured-light depth camera, 4 depth cameras, 8 ultrasonic radars, 2 LiDARs, 6-axis IMU |
| Audio | 5 W speaker |
| End Effectors | Confirm at quote |
| Travel Speed | Confirm at quote |
Industries
Frequently Asked Questions
Mobile manipulation: collaborative embodied AI work, laboratory automation and commercial service tasks where a robot has to move between stations and then handle objects accurately.
Repeat positioning accuracy is plus or minus 0.1 millimetre, and the two arms together are rated for a 16-kilogram payload.
Runtime is four hours from two 720 watt-hour packs. The batteries are hot-swappable, so a charged pair can replace a depleted one instead of waiting about two hours for a recharge.
Ubuntu 22.04 on an AMD Ryzen processor, with an optional Jetson AGX Orin or Thor module where heavier model inference is needed.
The 29 degrees of freedom quoted exclude end effectors. Grippers or hands are selected for the application and confirmed with the quotation.
The Fourier GRW Wheeled Bi-Arm Robot is priced at 370.990 lei in your market.
Recently Viewed
You haven't viewed any products yet.